01
Mobility
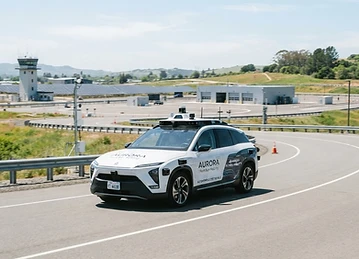
Perception for vehicles that move
ADAS-grade stereo and time-of-flight optics, multispectral lane and object recognition, and ruggedized vision units built for vibration, spray, and thermal cycling.
Optical sensor integration / 002
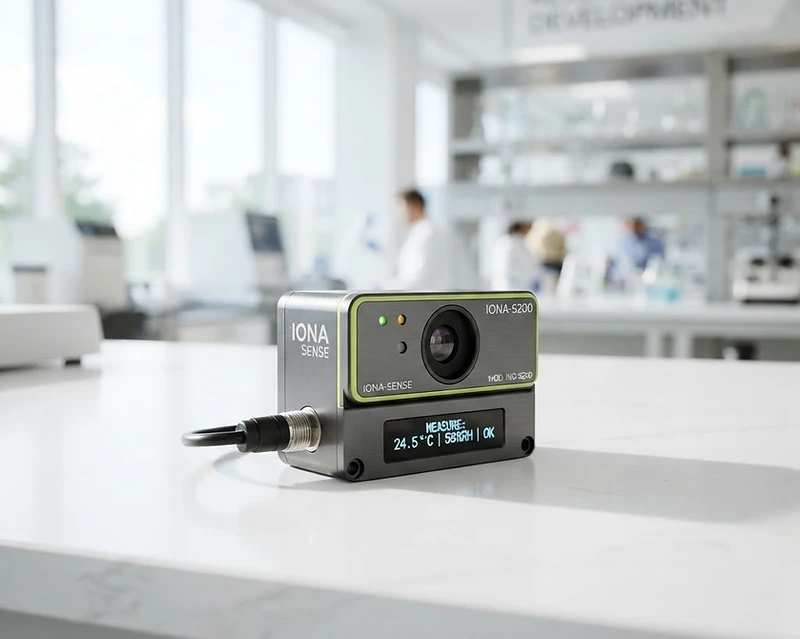
A unified optical perception platform engineered for the field — mobility, smart cities, power plants, and robotics share one stack of sensors, edge compute, and mathematically safe control.
Explore the domains[01] Application domains
Perception for vehicles that move
ADAS-grade stereo and time-of-flight optics, multispectral lane and object recognition, and ruggedized vision units built for vibration, spray, and thermal cycling.

A distributed vision mesh
Federated edge nodes fuse traffic, air-quality, and adaptive lighting streams with on-device, privacy-preserving inference — no raw frames leave the intersection.
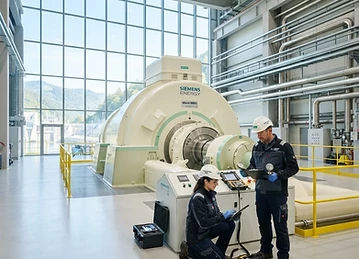
Critical infrastructure under watch
Thermal and UV imaging for boilers, turbines, and substations; predictive corrosion and corona detection; IP67 vision in hazardous and high-EMI zones.
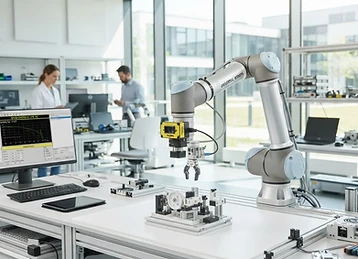
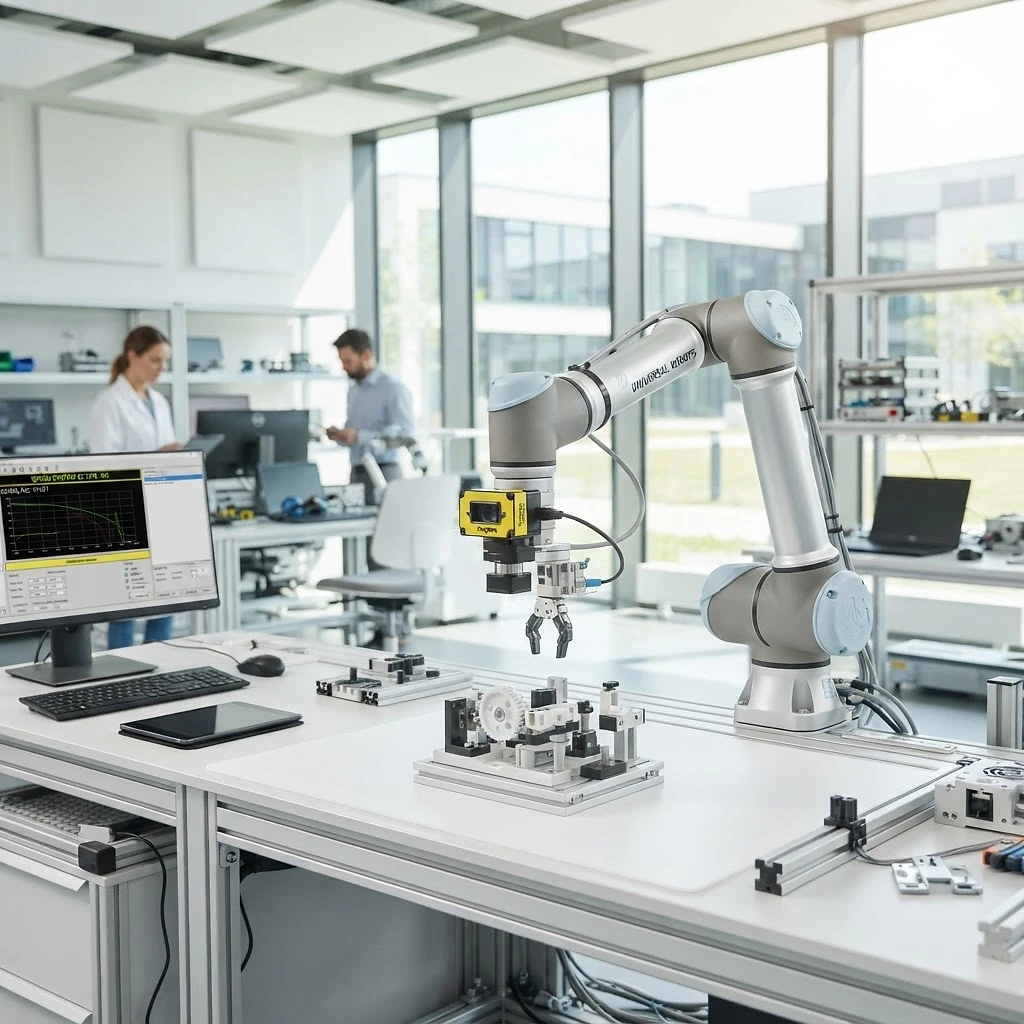
Eyes for autonomous motion
6-DoF pose estimation, depth + RGB fusion for bin picking, and safety-rated perception that lets collaborative arms and mobile robots operate inside the safe envelope.
[02] The stack
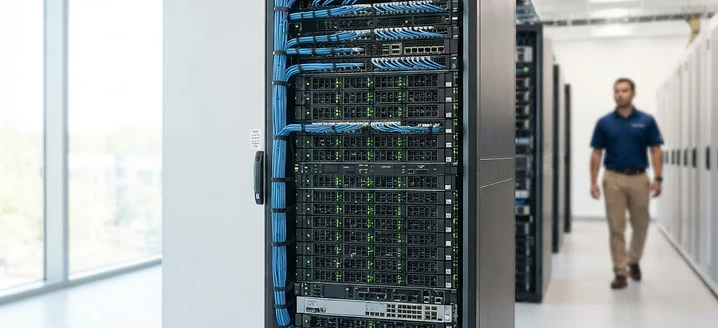
Multispectral and stereo optics, ToF, thermal, UV, and acoustic sensors behind IP67 housings with anti-biofouling and vibration isolation.
[03] Network & compliance
Engineering process
On-device, privacy-preserving inference
Ruggedized ingress protection
German Research Allowance
[AgTech] Moving edge perception
A fleet of moving edge device cameras — motorized, multispectral, and on-device — turning large-scale agricultural deployments into a single, verifiable perception field.
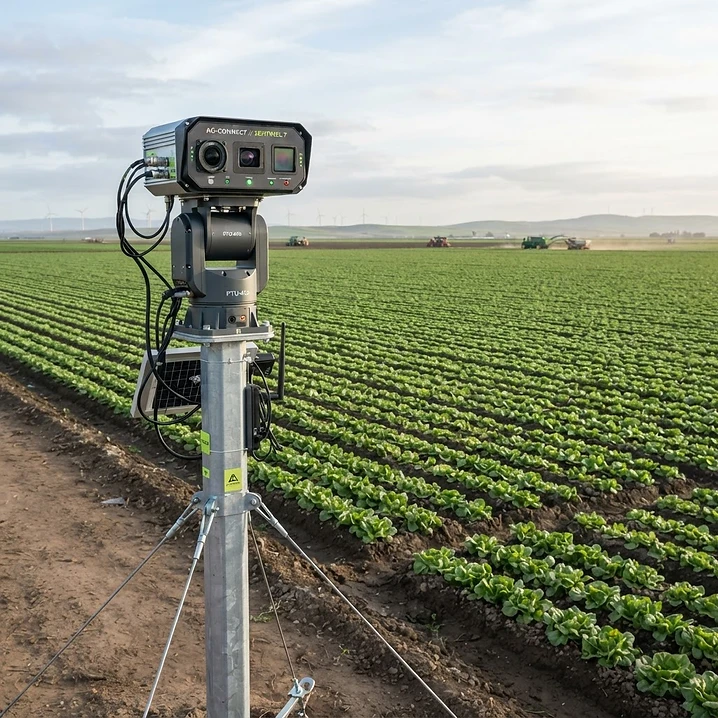
Edge-camera units move and re-aim across a cultivation site rather than sitting fixed. Each unit fuses RGB and near-infrared streams, runs visual algorithms on-device, and hands structured telemetry back to OptiVX — covering thousands of rows with a fraction of the hardware of a static-camera grid.
Roving edge cameras that re-frame coverage as crop zones evolve.
Models run locally on the camera unit — no round-trip to the cloud.
RGB + NIR combine into a single, mathematically safe perception stream.
Camera-to-camera coordination across a large-scale deployment fleet.
Plant-level segmentation and growth-stage inference across thousands of rows in real time.
Multispectral lesion classification with bounded false-positive control on the edge.
Dense canopy estimation feeding back into the OptiVX optimization loop.
RL-driven camera re-orientation toward regions of declining confidence.
[03] Deploy with Gemino AI
From a single intersection to a fleet of vehicles, the platform deploys as one reference architecture calibrated for your domain.
hello@gemino.ai[Summit] EX-AI Summit 2026
18-20 November / Online / Las Palmas / Bali